Isaac ROS Teleop#
Overview#
Isaac ROS Teleop contains a ROS 2 package for robot data collection.
isaac_ros_teleop relies on Isaac Teleop, a framework
for high-fidelity ego-centric and robot data collection. Isaac Teleop is designed to address the
data bottleneck in robot learning by streamlining device integration, allowing for high-fidelity human
demo data collection, and fosters device and data interoperability.
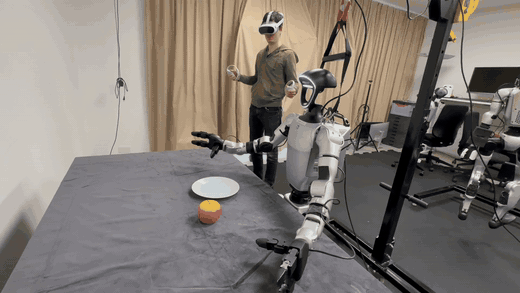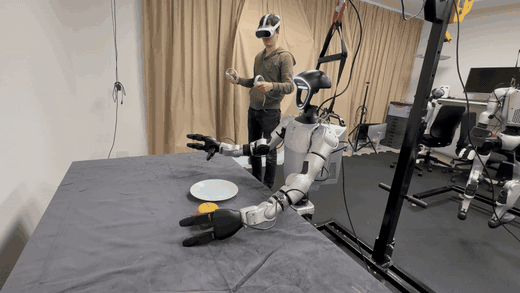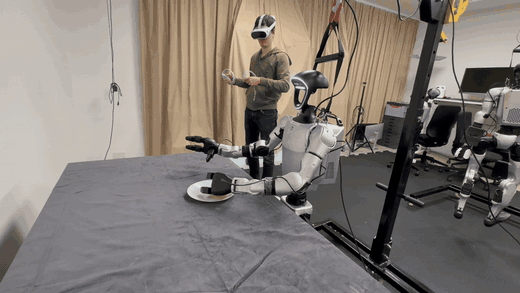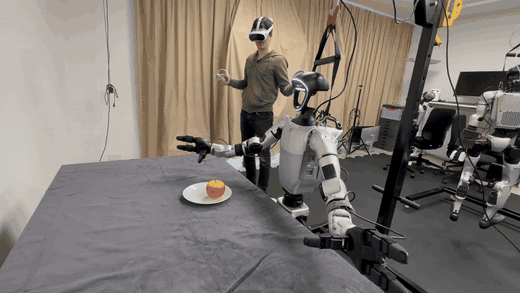
This repository is focused on using XR headsets for gripper or tri-finger hand manipulation using the PICO 4 Ultra or Meta Quest 3 headset.
Quickstarts#
Packages#
Supported Platforms#
This package is designed and tested to be compatible with ROS 2 Lyrical running on Jetson or an x86_64 system with an NVIDIA GPU.
Platform |
Hardware |
Software |
Storage |
Notes |
|---|---|---|---|---|
Jetson |
128+ GB NVMe SSD |
For best performance, ensure that power settings are configured appropriately for your platform: Jetson Thor power settings or Jetson Orin power settings. |
||
x86_64 |
|
32+ GB disk space available |
Isaac ROS Environment#
To simplify development, we strongly recommend leveraging the Isaac ROS CLI by following these steps. This streamlines your development environment setup with the correct versions of dependencies on all supported platforms.
Note
All Isaac ROS Quickstarts, tutorials, and examples have been designed with the Isaac ROS CLI-managed environment as a prerequisite.
Customize your Dev Environment#
To customize your development environment, refer to this guide.
Updates#
Date |
Changes |
|---|---|
2026-09-21 |
Publish end-effector poses as |
2026-08-18 |
Support auto-launching CloudXR via the node, publish head pose, and add |
2026-07-06 |
Added Docker-free CloudXR runtime support, Meta Quest 3 headset support, raw controller data publishing, configurable XR pose transforms, RViz visualization, and updated PoseArray hand order |
2026-04-30 |
Initial release of |